Applications / Optical flow · ego-motion · visual navigation
Navigation that does not wait for a frame
Optical flow, ego-motion removal and visual navigation for robots and uncrewed platforms that move fast, work in poor light, or cannot count on GPS.
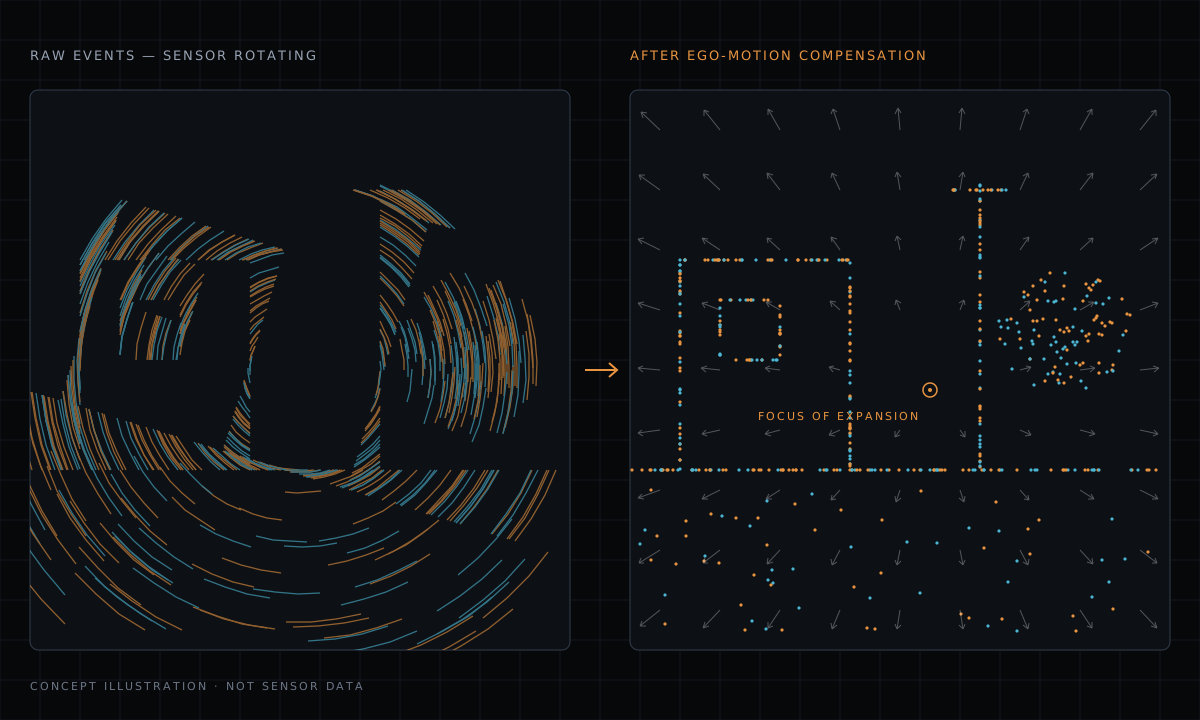
The problem
Vision fails when the platform needs it most
Fast motion smears frames. Low light stretches exposures and makes it worse. Glare and shadow saturate one part of the image while the rest goes dark. Those are the conditions where a robot most needs its eyes, and where frame-based visual navigation loses lock.
Without GPS, the camera is often the only external reference left.
Why event sensing
Evidence
What we have shown
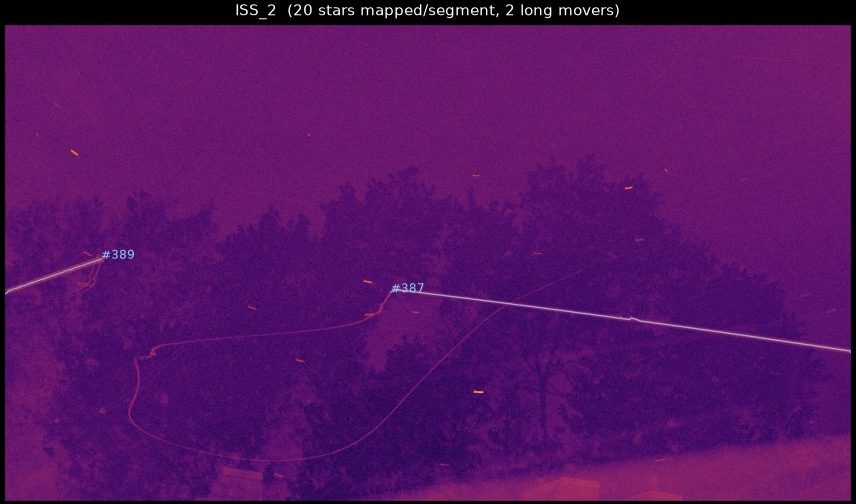
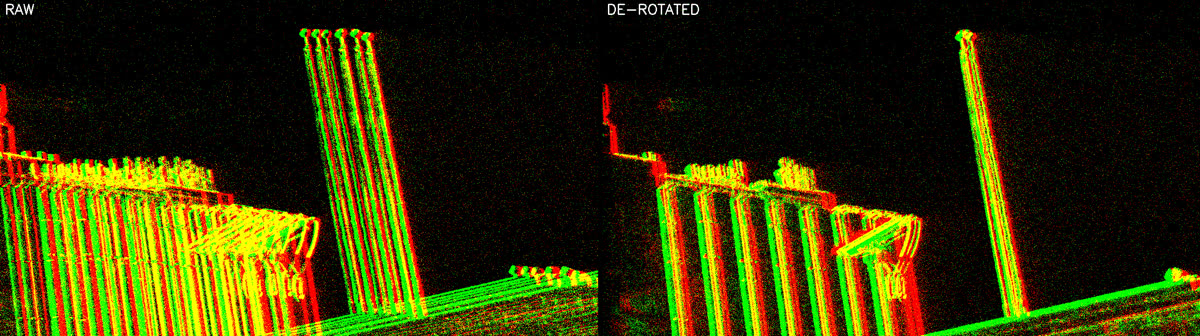
A rotating sensor’s raw events next to the same events after de-rotation, and a satellite track held while the camera was turned by hand.
Own a program in this space?
If size, power, cost or a frame sensor’s limits are what stand between you and the requirement, we would like to hear about it.