Applications / Counter-UAS · fixed site and maneuver

Passive watch for the point you have to hold

A ground-based detect-and-track sensor for fixed sites and maneuver elements, built to cue the fire control system you already field rather than replace it.
Field-demonstratedTRL 5/6 · ONR Wave Breaker, Key West, May 2026
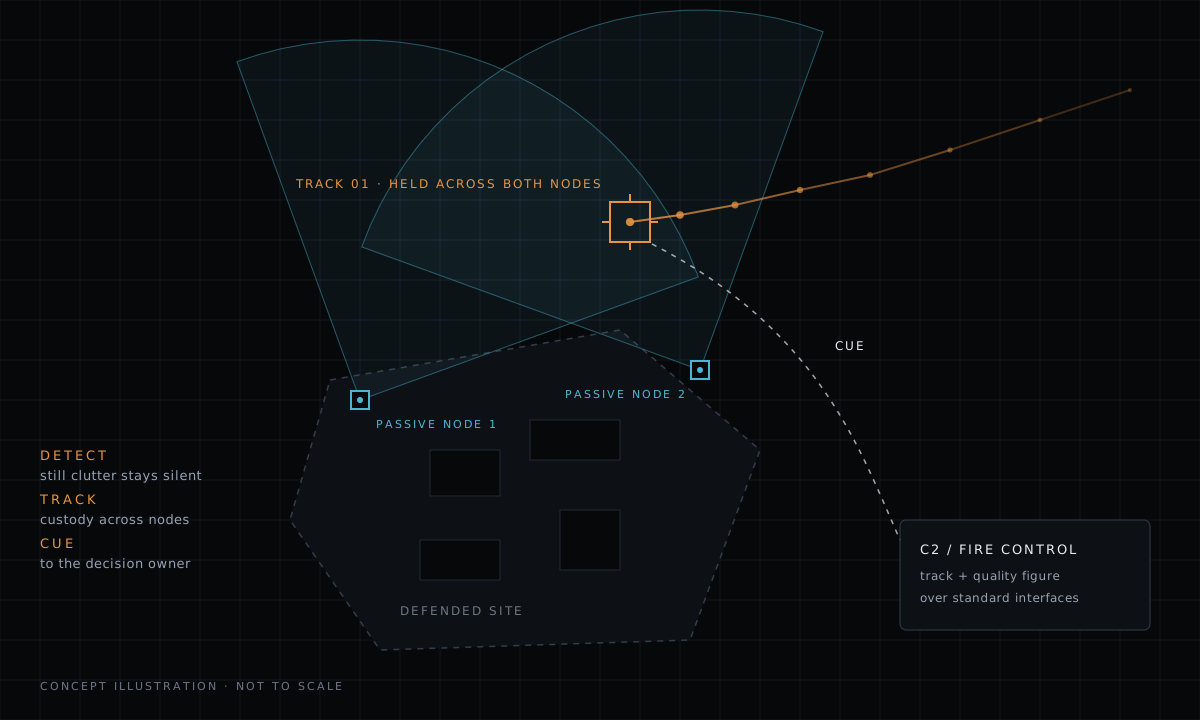
Concept illustration: two passive sensor nodes cover a defended site, hold one track on an inbound small drone across both fields of view, and cue it to command and control
Concept. Passive nodes detect and hold the track; the cue goes to whichever fire control system owns the decision.

The problem

Small, low and hidden in the background

A small drone is a handful of pixels against a treeline, a skyline or a busy sky. It flies low, under the coverage that was built for larger aircraft, and it is cheap enough to come in numbers.

Holding a point against that takes persistent coverage from many sensors, not one exquisite one. Every node has to be affordable, quiet and easy to place.

Why event sensing

PassiveNothing radiates. A node gives an adversary nothing to locate or jam.
Clutter goes quietA still background produces no events. What reaches the tracker is already motion, so a small mover stands out from foliage and structure.
Custody across nodesOne track identity is handed between sensors as the target crosses their fields of view.
Cue, not replaceOutput is a track with a quality figure, over standard interfaces, to whichever C2 or fire control system owns the decision.
Priced for coverageSensor and processing on one low-power module, so adding nodes is a budget decision, not a program.

Evidence

What we have shown

Taken to sea on a U.S. Navy vessel at ONR Wave Breaker, then run on our own range against small UAS in clutter. Clips are unedited field recordings; the overlay is the system’s live output.
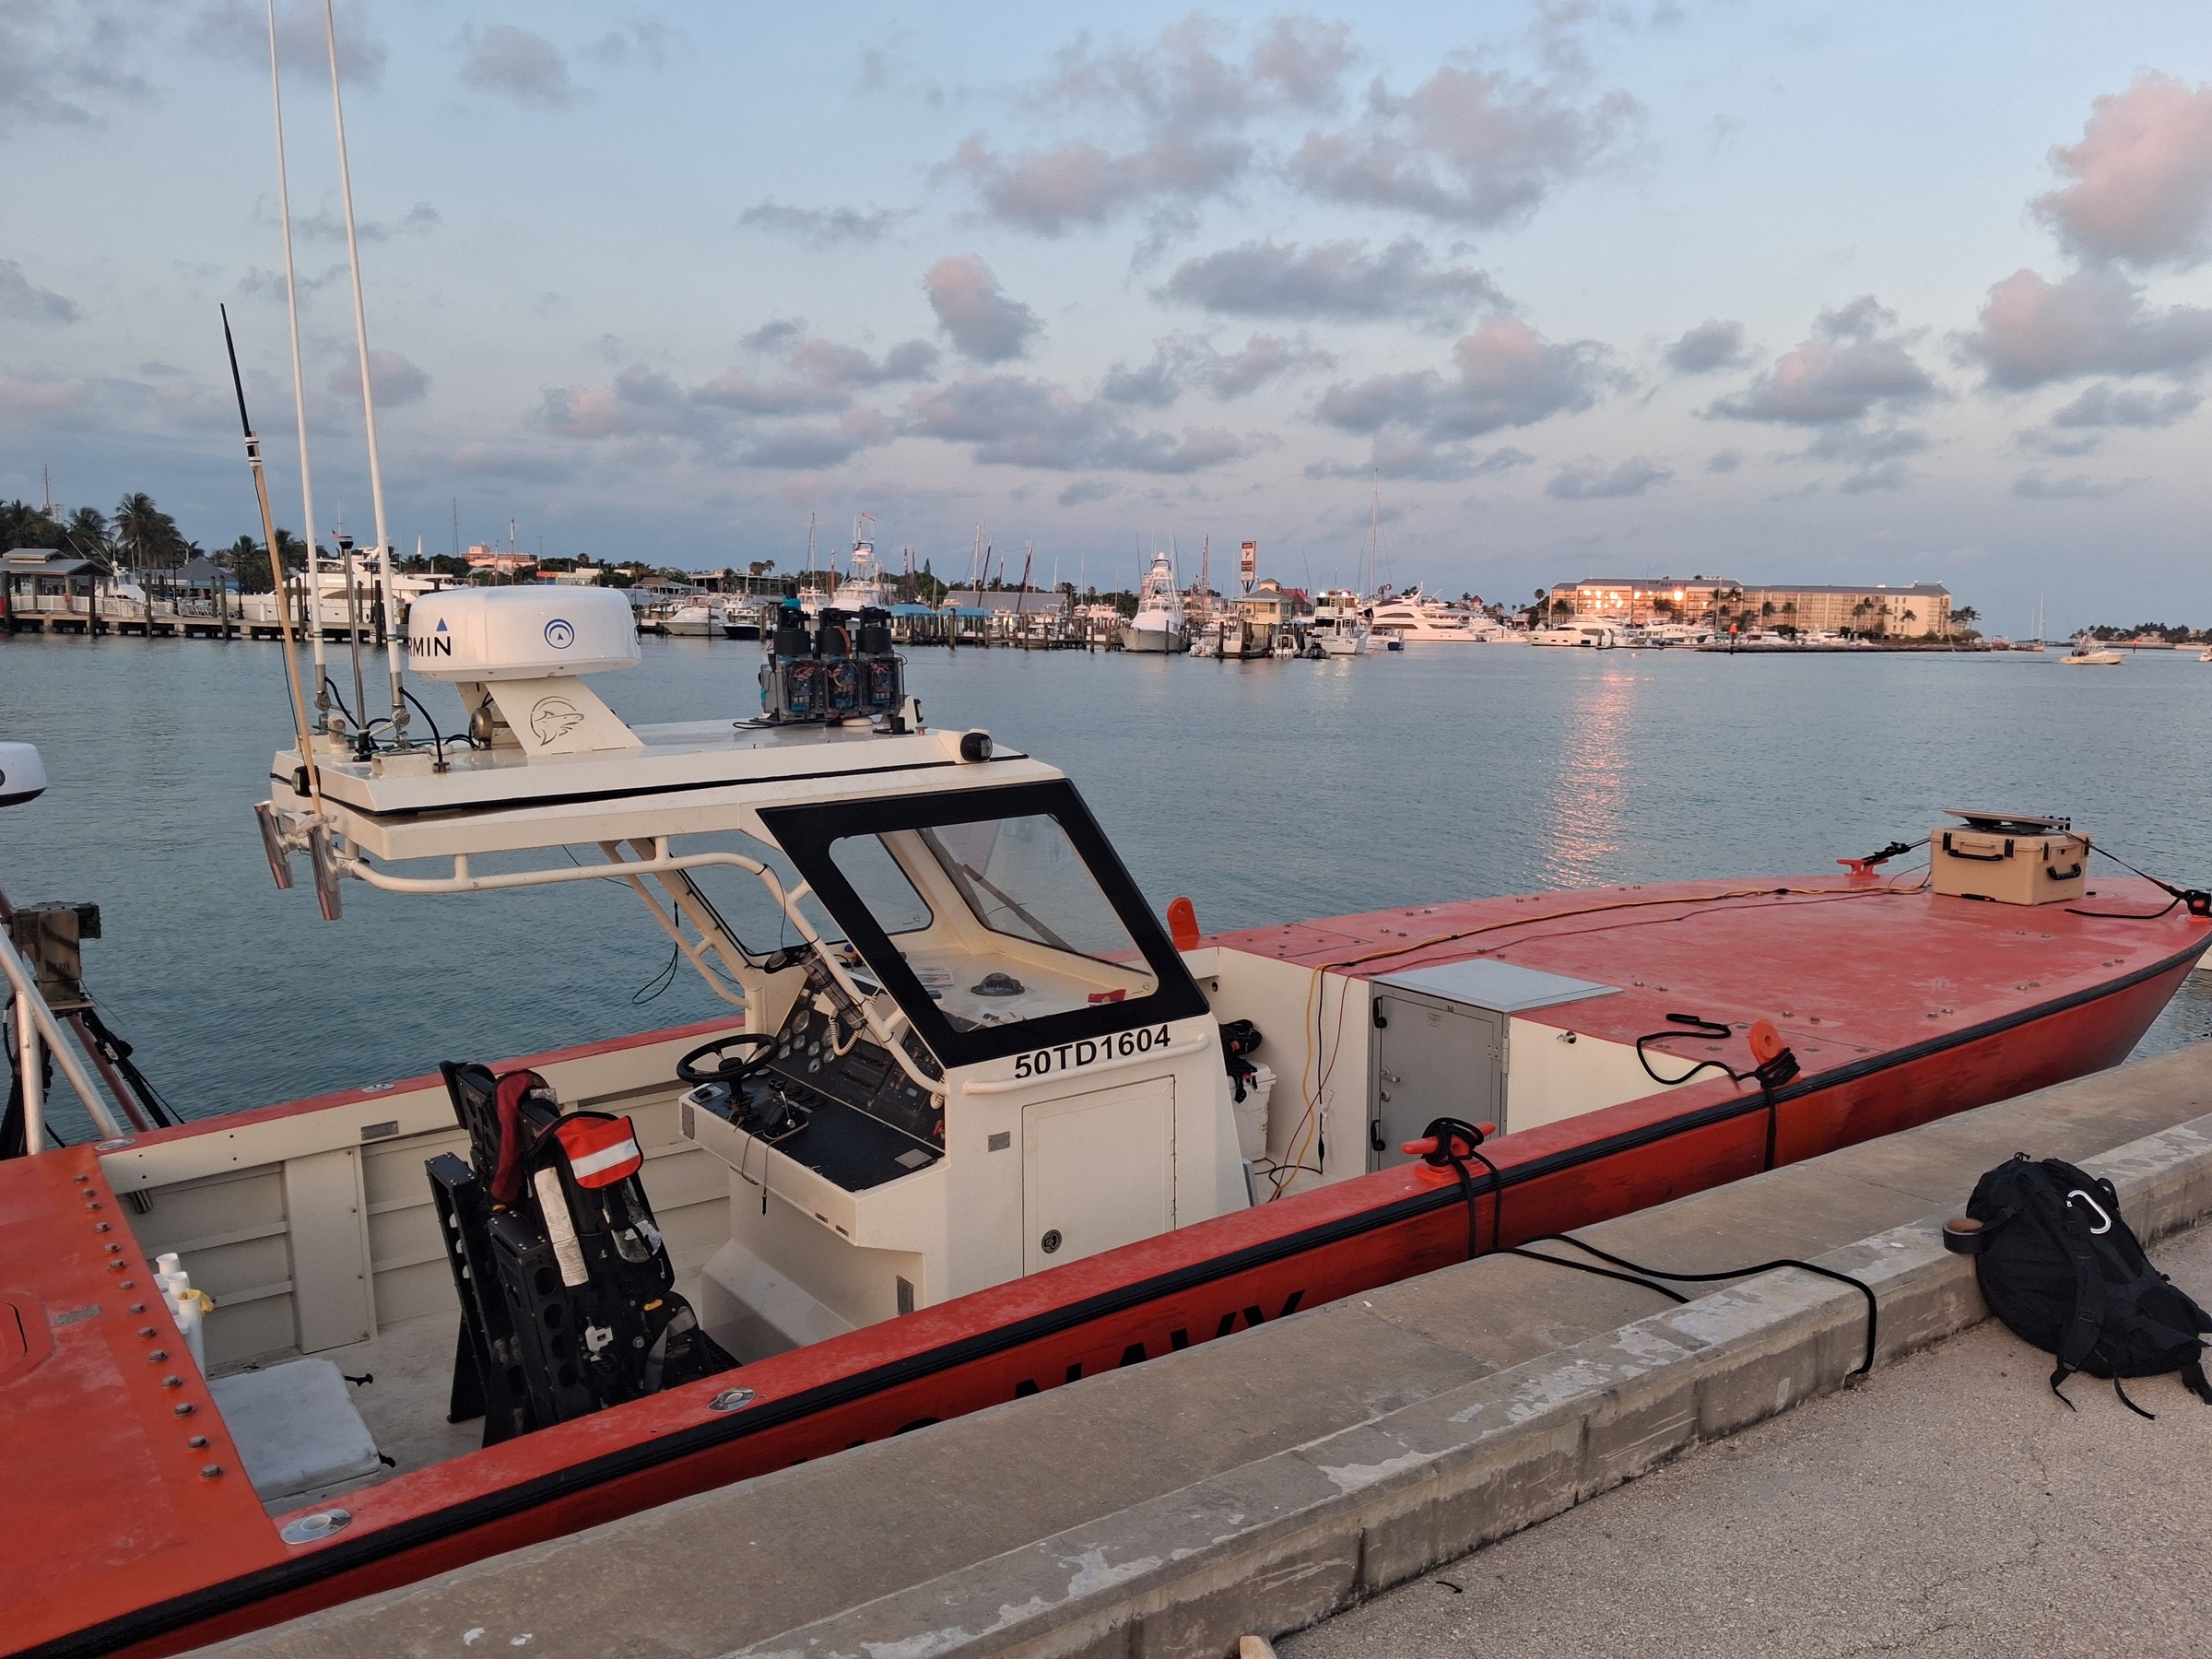
Balor event-based sensor system mast-mounted aboard a U.S. Navy vessel at ONR Wave Breaker, Key West FL, May 2026
May 2026Mast-mounted on a U.S. Navy vessel at ONR Wave Breaker, Key West, FL, May 2026.
Small UAS held against a moving treeline. Unedited field recording; the overlay is the system's live output.
Small UAS against bright sky and cloud, tracked on the module.
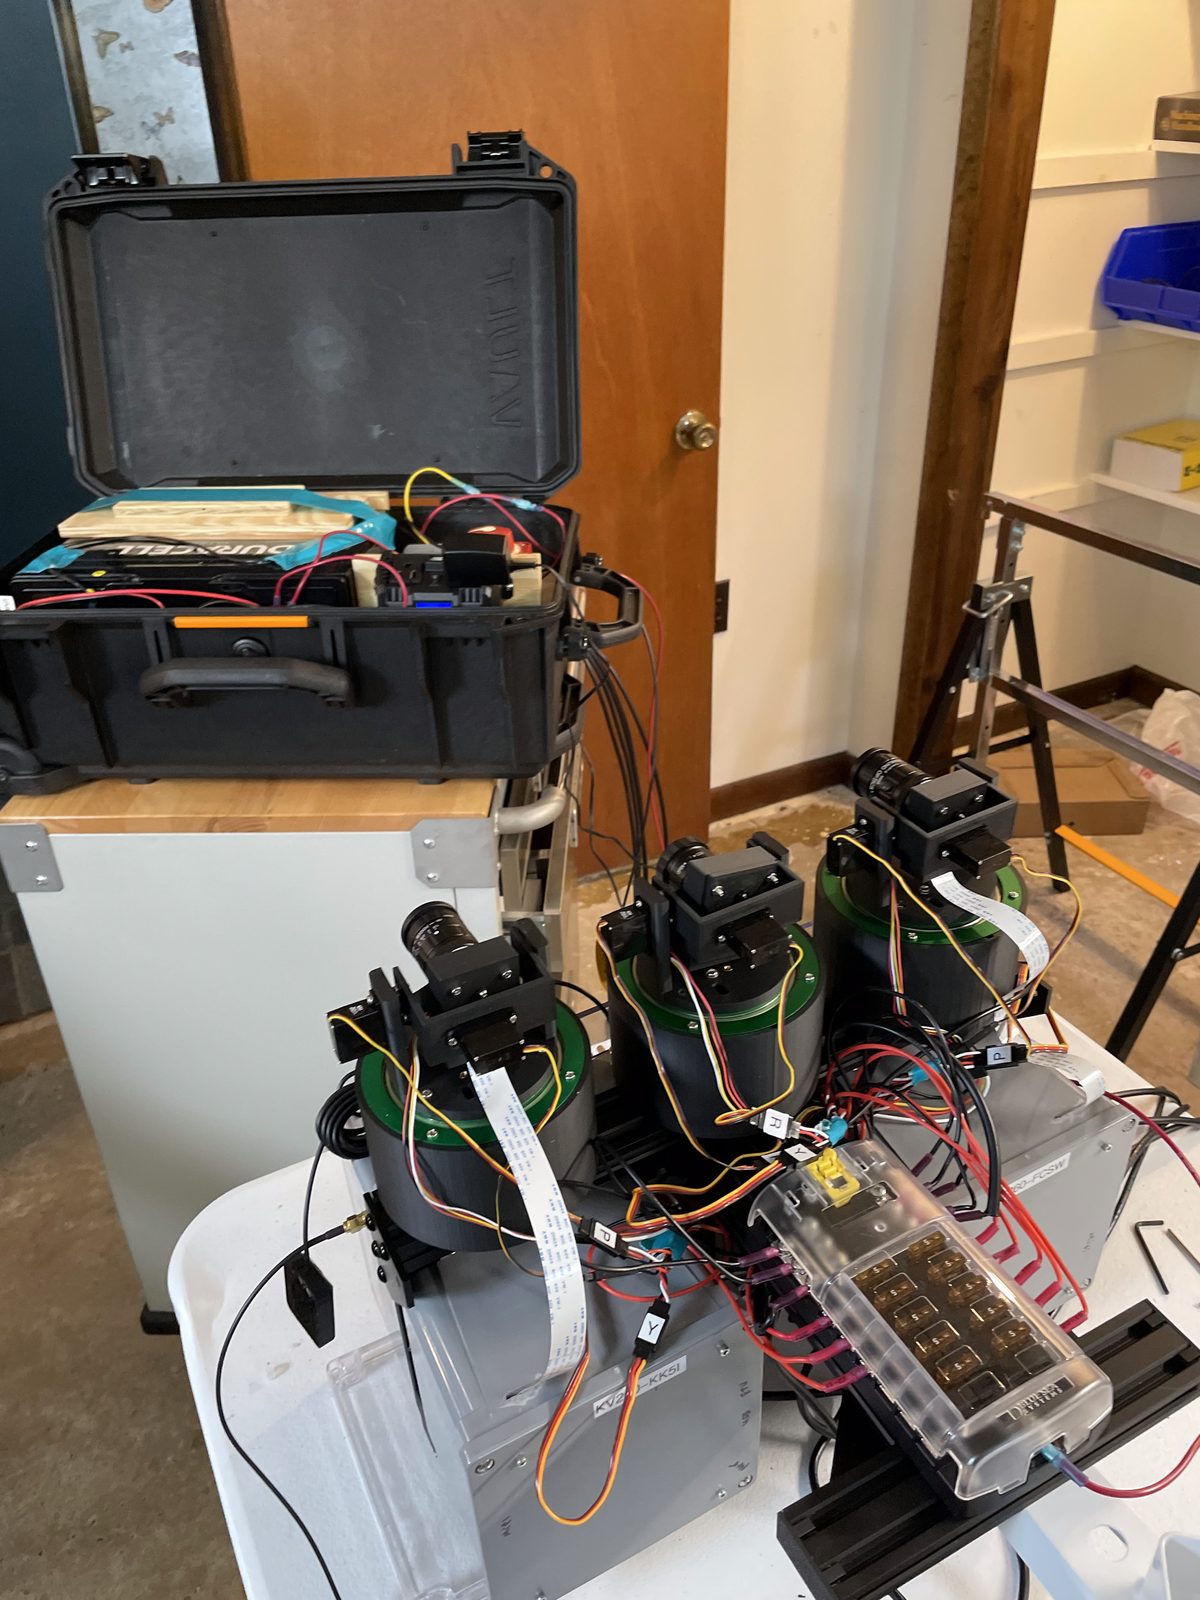
Three gimbal-stabilized camera units on the bench before the Wave Breaker boat test
May 2026The sea-test build on the bench: three gimbal-stabilized camera heads, two event and one frame, before shipping to Key West.
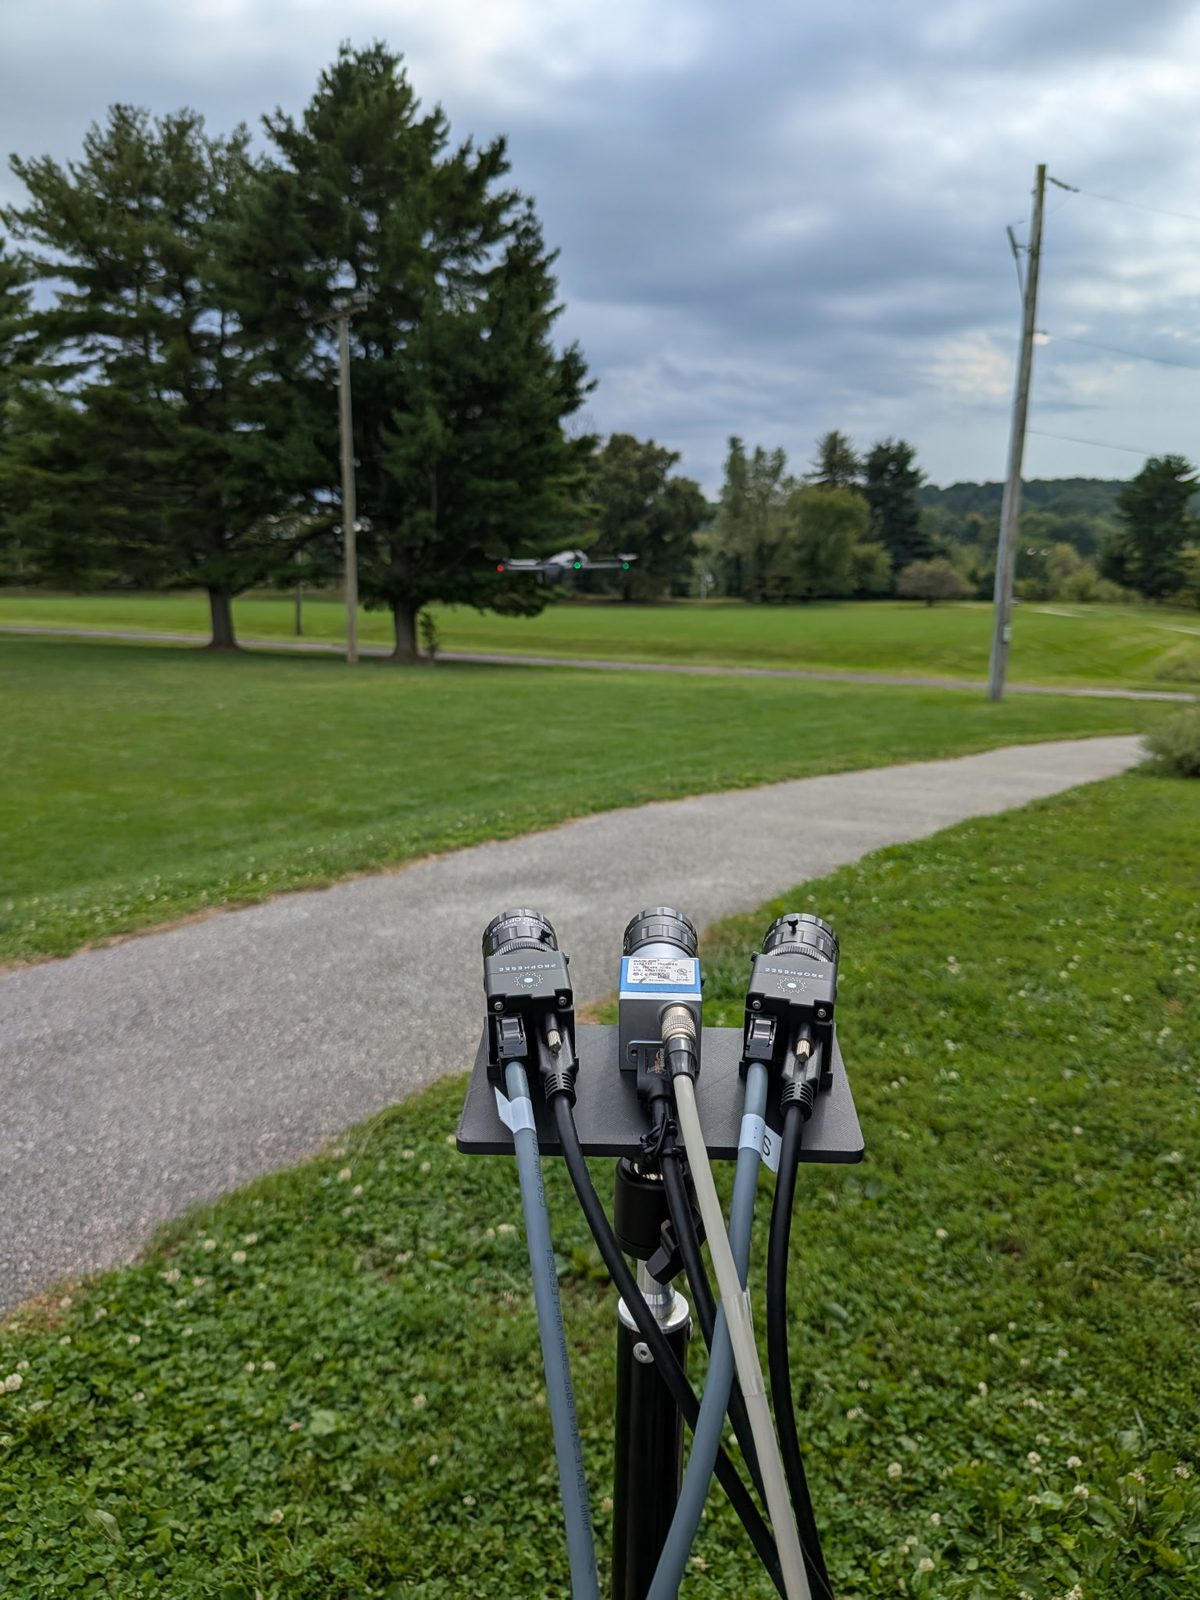
Tripod-mounted event and frame camera rig in a field with a multirotor airborne in the background
Sep 2026Field collection on our own range: target airborne, sensor head recording.
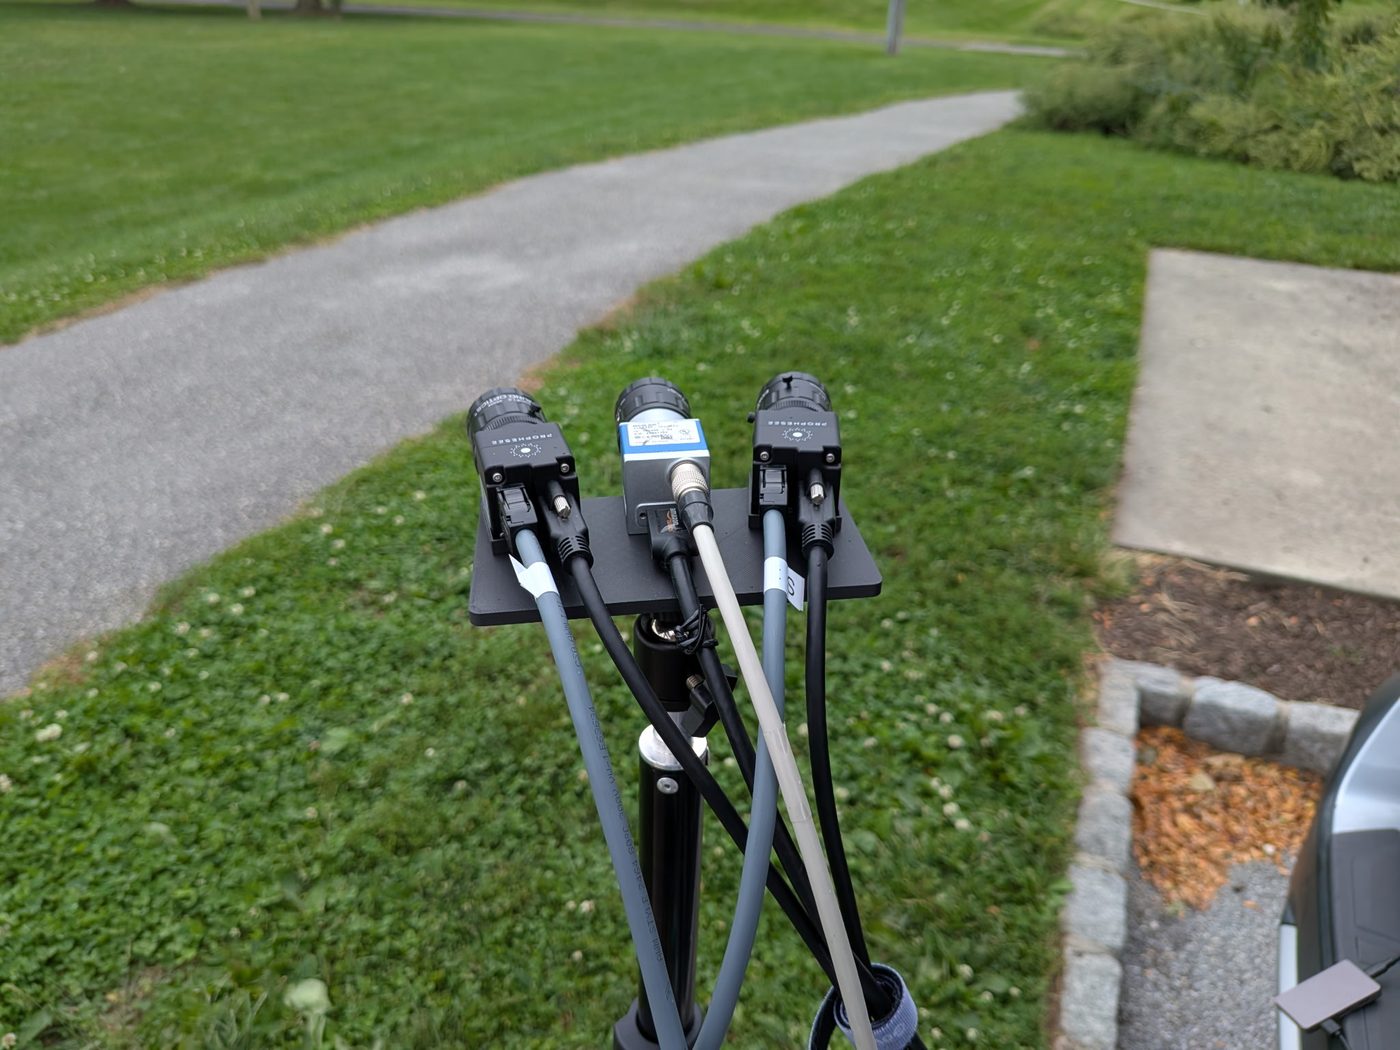
Three-camera sensor head: two event cameras flanking a frame camera on a common plate
Sep 2026Dual-modality head: two event cameras flanking a frame camera on a shared timebase, toed out for wider azimuth coverage.

Export control. This page describes capability only. Performance, integration and technical data are exchanged against a specific requirement under appropriate agreement and authorization, not published here.

Own a program in this space?

If size, power, cost or a frame sensor’s limits are what stand between you and the requirement, we would like to hear about it.